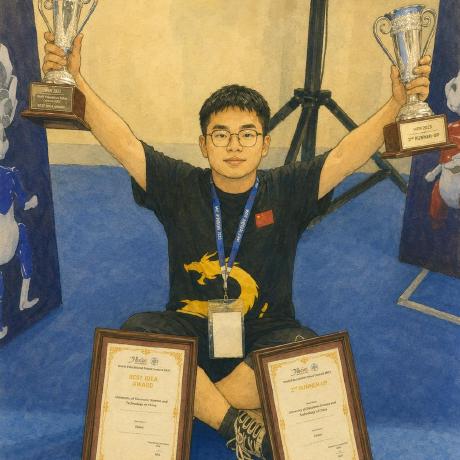
Portrait of Pengyu Jing holding robotics competition trophies

Robot Learning · Manipulation

Pengyu Jing

Ph.D. Student in Electrical and Computer Engineering at the National University of Singapore

I work on robot learning and robotic manipulation, with an emphasis on reinforcement learning, vision-language-action models, simulation, and real-robot systems.

I received my M.Sc. in Robotics from the National University of Singapore and my B.Eng. in Robotics Engineering from the University of Electronic Science and Technology of China.

Goal: Build reliable robots that can learn, adapt, and improve through real-world interaction.

Research interests: robotic manipulation, reinforcement learning, vision-language-action models, and sim-to-real transfer.

News

Selected Publications

RARM: Confidence-Gated Progress Reward Modeling for RL in Manipulation

Pengzhi Yang*, Xinyu Wang*, Pengyu Jing*, Kehan Wen*, Yiduo Qu, Zhenhao Huang, Minghao Fu, Xin Liu, Yaheng Shen, Fan Shi

Conference on Robot Learning (CoRL), 2026

A lightweight visual comparator that turns one successful demonstration into a dense reward while suppressing uncertain progress estimates that may cause reward hacking.

DiagGen: Agentic Generation of Deformable Assets with Sim-based Diagnostics for Robotic Simulation

Guanxiong Chen*, Yiduo Qu*, Qianjun Xia*, Pengyu Jing, Yixian Cheng, Bole Ma, Pengzhi Yang, Bingyang Zhou, Ziming Li, Shashwat Suri, Gongbo Sun, Chao Liu, Peter Yichen Chen, Ziqiu Zeng, Fan Shi

arXiv preprint, 2026

An agentic framework that turns a single in-the-wild image into a simulation-ready deformable asset through a generate–simulate–diagnose–refine loop, using simulated material responses to repair upstream generation errors.

Agentic Real2Sim: Physics-based World Modeling with Vision-Language Agents

Guanxiong Chen*, Qianjun Xia*, Jiawei Peng*, Heng Zhang*, Pengyu Jing*, Bole Ma*, Justin Qian, Yixian Cheng, Ziyi Jiao, Bingyang Zhou, Yiduo Qu, Luoxin Ye, Kaifeng Zhang, Kunyi Wang, Weijia Zeng, Yunuo Chen, Pengzhi Yang, Ziqiu Zeng, Siyuan Luo, Huamin Wang, Chao Liu, Alan Yuille, Fan Shi, Changxi Zheng, Yunzhu Li, Chenfanfu Jiang, Peter Yichen Chen

arXiv preprint, 2026

A vision-language agent framework that converts a real-world recording of object–robot interaction into a simulatable episodic twin, supporting downstream policy fine-tuning and evaluation.

Additional Publications

  1. Design and Testing of a Pleurotus pulmonarius Stick Cutting Machine. Agriculture, 14(10):1795, 2024.
  2. An Intermittent Fertilization Control System for Fruit Tree Crown Detection. Agriculture, 14(11):1867, 2024.

Selected Experience

2025–2026

Robot Learning and Manipulation Research · NUS

Built VLA data-collection and real-robot rollout infrastructure, reproduced real-world RL baselines, integrated human intervention, and evaluated dense progress rewards on dual-arm manipulation tasks.

2022–2023

Electrical Group Leader · UESTC Robocon Team

Led the electrical subsystem of the national-champion elephant and bunny robots, owning the control architecture, distributed real-time communication, state estimation, and field-oriented actuation stack end to end.

Honors & Awards

Competition highlights of the elephant and bunny robots from the UESTC Robocon 2023 team.
National ChampionChina National Robocon, 2023
Best Design AwardChina National Robocon, 2023
Third PlaceABU Asia-Pacific Robot Contest, 2023
Best Design AwardABU Asia-Pacific Robot Contest, 2023

Technical Background

PythonC/C++MATLAB PyTorchVLA ROS / ROS 2MuJoCoIsaac Sim STM32CANPCB DesignEmbedded SystemsSolidWorks